Portrait of NomadJoe

FIELD NOTES FROM THE LONG ASCENT

NOMADJOE

TO FEEL. TO EXPERIENCE. 感其生,历其境。

Notes on machines, failure, and continuing forward.

PROJECT LEDGER

Project collection

09 FIELD RECORDS
02 Team project 2026.07—2026.08

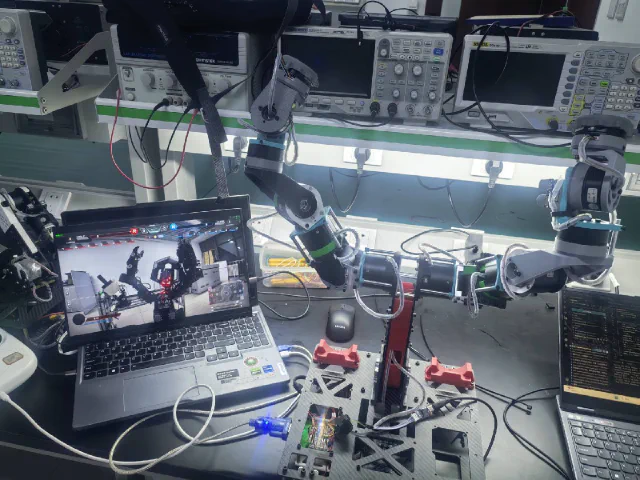
Humanoid Dual-Arm Teleoperation Controller

Embedded Lead · Operator-Side Architecture and Control Pipeline Development

14-DOF dual-arm teleoperation controller integration test

Structured the fourteen-joint mapping and state-acquisition pipeline for the dual-arm operator side, and implemented a command-delivery framework for MIT force-position control. Added gravity compensation to the control pipeline and used Python/MATLAB for gravity-compensation parameter identification and offline validation. The current scope covers only the enabled compensation and validation work.

  • STM32G474
  • C++17
  • FreeRTOS
  • FDCAN
  • Python
  • MATLAB
03 Team project 2025.08—2026.07

Single 6-Axis Arm Engineering Robot

Embedded Lead · Code Architecture, Algorithm Development, and Performance Optimization

RoboMaster single-arm engineering robot

Built a layered control pipeline covering inverse kinematics, trajectories, gravity compensation, and coordinated safety handling. Used SystemView and Cache/ITCM observations to locate performance behavior, then continued improving the architecture and algorithms.

  • STM32H723
  • C++17
  • FreeRTOS
  • SystemView
  • ITCM
04 Team project 2025.08—2025.10

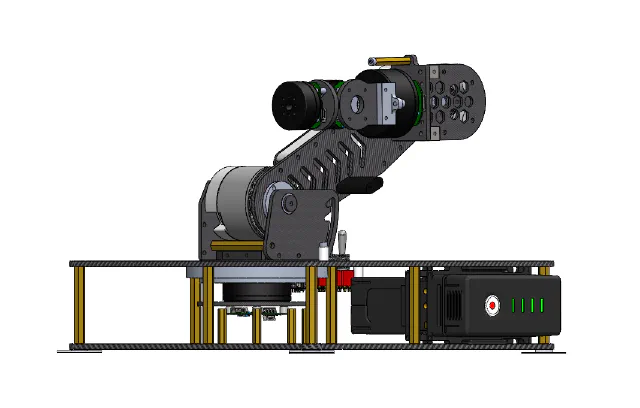
6-DOF Custom Controller

Embedded Lead · Controller System Design and Validation

Side-view CAD rendering of the 6-DOF custom controller

Built interfaces for teleoperation, joint-to-motor mapping, multitask control, display, and parameter interaction. Completed gravity-compensation parameter identification and incorporated gravity-compensation and damping interfaces into the validation framework, making it easier to check how the control pipeline works together step by step.

  • STM32G474
  • C++17
  • FreeRTOS
  • FDCAN
  • CMSIS-DSP
SOFTWARE RECORDS
05 Personal project 2025.10—2025.11

MotorLib

Driver Abstraction and CAN Management

Implemented a driver abstraction and CAN management exercise for up to four DJI motors. Organized objects with a fixed-capacity registration mechanism and completed the basic frame-packing and receive-dispatch pipeline.

  • STM32
  • C++
  • FreeRTOS
  • CAN
  • ETL
06 Personal project 2025.11—2026.02

ChipTanks

System Architecture and Full Implementation

Built a tank game that runs on a 128×64 OLED, with the update process organized as a task loop. Used fixed-capacity entity management to connect the OLED display, input, and game-state processing pipeline.

  • STM32F103
  • C/C++
  • FreeRTOS
  • ETL
  • OLED
07 Team project 2025.05—2025.11

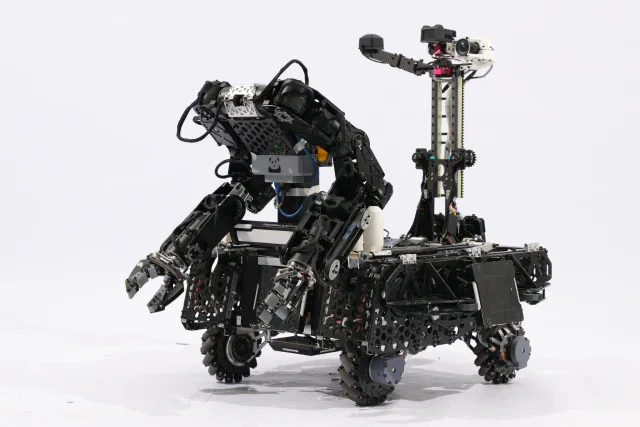
RoboMaster 2025 Engineering Robot

Project Member · Arm Algorithm Optimization, Code Refactoring, and Vehicle Wiring Optimization

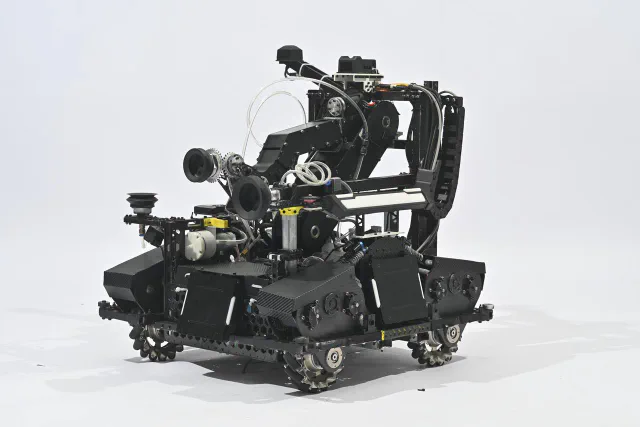
RoboMaster 2025 engineering robot

Contributed to later iterations of the engineering robot’s arm and control system. My main responsibilities were optimizing gravity compensation and six-axis inverse kinematics, refactoring arm-control code, and building the initial arm components. I also reorganized and optimized the vehicle wiring.

  • STM32
  • C++
  • FreeRTOS
  • CAN/FDCAN
  • Robot-Arm Kinematics
  • Gravity Compensation
08 Team project 2024.12—2025.04

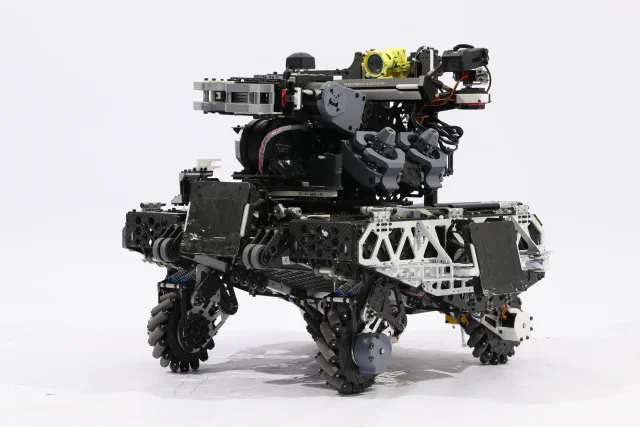
RoboMaster 2024 Engineering Robot

Project Member · Code Maintenance, Application Features, and Chassis Control Optimization

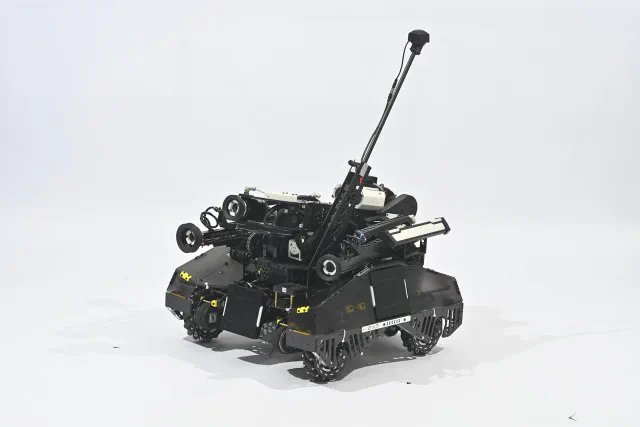
RoboMaster 2024 engineering robot

Contributed to development and maintenance during the RoboMaster 2025 regional competition stage. This robot served as the backup vehicle; my main responsibilities were maintaining competition code and developing the fixed-position pickup and placement application. I also maintained cabling, optimized inverse kinematics for the wheel system, and tuned PID parameters.

  • STM32
  • C/C++
  • FreeRTOS
  • CAN
  • PID
  • Wheel-System Kinematics
09 Personal project 2024.08—2024.10

RM Infantry Robot

Embedded Control System Design and Implementation

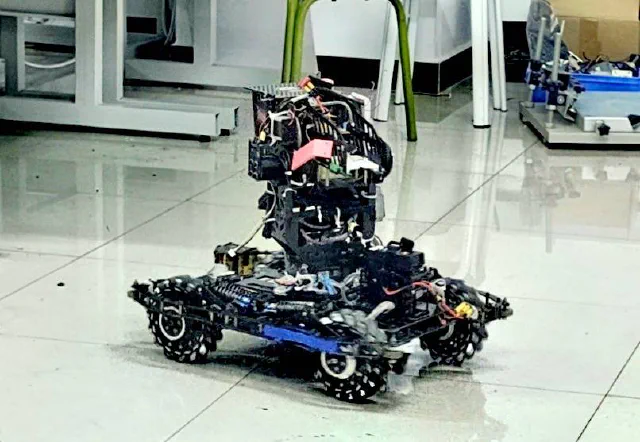
RM infantry robot

Independently designed and implemented the embedded control system for an RM infantry robot, covering the chassis, gimbal, remote control, PID, CAN/FDCAN communication, and attitude estimation modules. Integrated the control pipeline and completed system-level testing.

  • STM32G473
  • C/C++
  • FreeRTOS
  • CAN/FDCAN
  • PID
  • AHRS

CHRONOLOGY

Timeline

  1. 2026.07—2026.08Project

    Humanoid Dual-Arm Teleoperation Controller

    Led embedded architecture and control-pipeline development for the dual-arm teleoperation side, completing fourteen-joint mapping, state acquisition, and MIT force-position control command delivery. Added gravity compensation and carried out parameter identification and compensation validation.

  2. 2026.03—2026.08Project

    Humanoid Dual 7R-Arm Engineering Robot

    Led architecture and algorithm development for the onboard control system of a humanoid dual 7R arm, integrating independent left- and right-arm control, kinematics solvers, model configuration, and the gravity-compensation pipeline.

  3. 2025.11—2026.02Personal

    ChipTanks

    Built an OLED-based tank game system with a game loop, fixed-capacity entity management, display, input, and state-processing pipeline.

  4. 2025.08—2026.07Project

    Single 6-Axis Arm Engineering Robot

    Led code architecture, algorithm development, and performance optimization for the single 6-axis arm control system, integrating the layered control pipeline, kinematics, trajectory, and gravity-compensation modules.

  5. 2025.08—2025.10Project

    6-DOF Custom Controller

    Led system design and validation for the 6-DOF custom controller, completing joint mapping, multitask coordination, parameter interaction, and gravity-compensation parameter identification, followed by integrated testing of gravity compensation and the control pipeline.

  6. 2025.10—2025.11Personal

    MotorLib

    Implemented driver abstraction and CAN management for up to four DJI motors, including fixed-capacity registration, frame packing, and the basic receive-dispatch pipeline.

  7. 2025.05—2025.11Project

    RoboMaster 2025 Engineering Robot

    Contributed to later iterations of the engineering robot’s arm and control system. My main responsibilities were optimizing gravity compensation and six-axis inverse kinematics, refactoring arm-control code, and building the initial arm components. I also reorganized and optimized the vehicle wiring.

  8. 2024.12—2025.04Project

    RoboMaster 2024 Engineering Robot

    Contributed to development and maintenance during the RoboMaster 2025 regional competition stage. This robot served as the backup vehicle; my main responsibilities were maintaining competition code and developing the fixed-position pickup and placement application. I also maintained cabling, optimized inverse kinematics for the wheel system, and tuned PID parameters.

  9. 2024.08—2024.10Personal

    RM Infantry Robot

    Independently designed and implemented the embedded control system for an RM infantry robot, completing the chassis, gimbal, remote control, PID, communication, attitude estimation, and full-vehicle control integration.

SYSTEM INVENTORY

Technology stack

Robotics and Control

  • DH / MDH Modeling
  • FK / IK
  • SEW Redundant Manipulator Solver
  • Weighted DLS
  • Trajectory Planning
  • Gravity Compensation
  • PID / MIT Control

Embedded Real-Time Systems

  • STM32 H7 / G4 / F1
  • FreeRTOS
  • CAN / FDCAN
  • UART DMA / Idle-Line Interrupt
  • CMSIS / CMSIS-DSP
  • Fixed-Capacity Resource Management

Programming Languages

  • C
  • C++
  • MATLAB
  • Python (Scripting and Validation)

Toolchains and Observability

  • CMake / arm-none-eabi
  • STM32CubeMX / Keil MDK
  • CLion / VS Code
  • Git
  • J-Link / Ozone
  • SystemView / DWT
  • Cache / ITCM / Map Analysis

RECENT LOG

Latest notes

View all

FIELD INDEX

Note index

Embedded systems and C++

  1. C&C++ Memory Alignment (Quick Guide)

Personal projects

Waiting for the next note.

Growth and observations

Waiting for the next note.